The description this design started from
A hexacopter agricultural mapping drone carrying a multispectral camera, 3 kg payload, brushless motors, GPS and IMU, 12 S LiPo, PA12 and carbon-fibre, flies over fields to survey crop health. Medium volume. BOM under 6000 USD.
This is a read-only example. Request a pilot to run your own robot.
Every tab shows this run exactly as Anubis left it, including the gates that blocked or failed. Nothing you do here starts a run or changes the design.
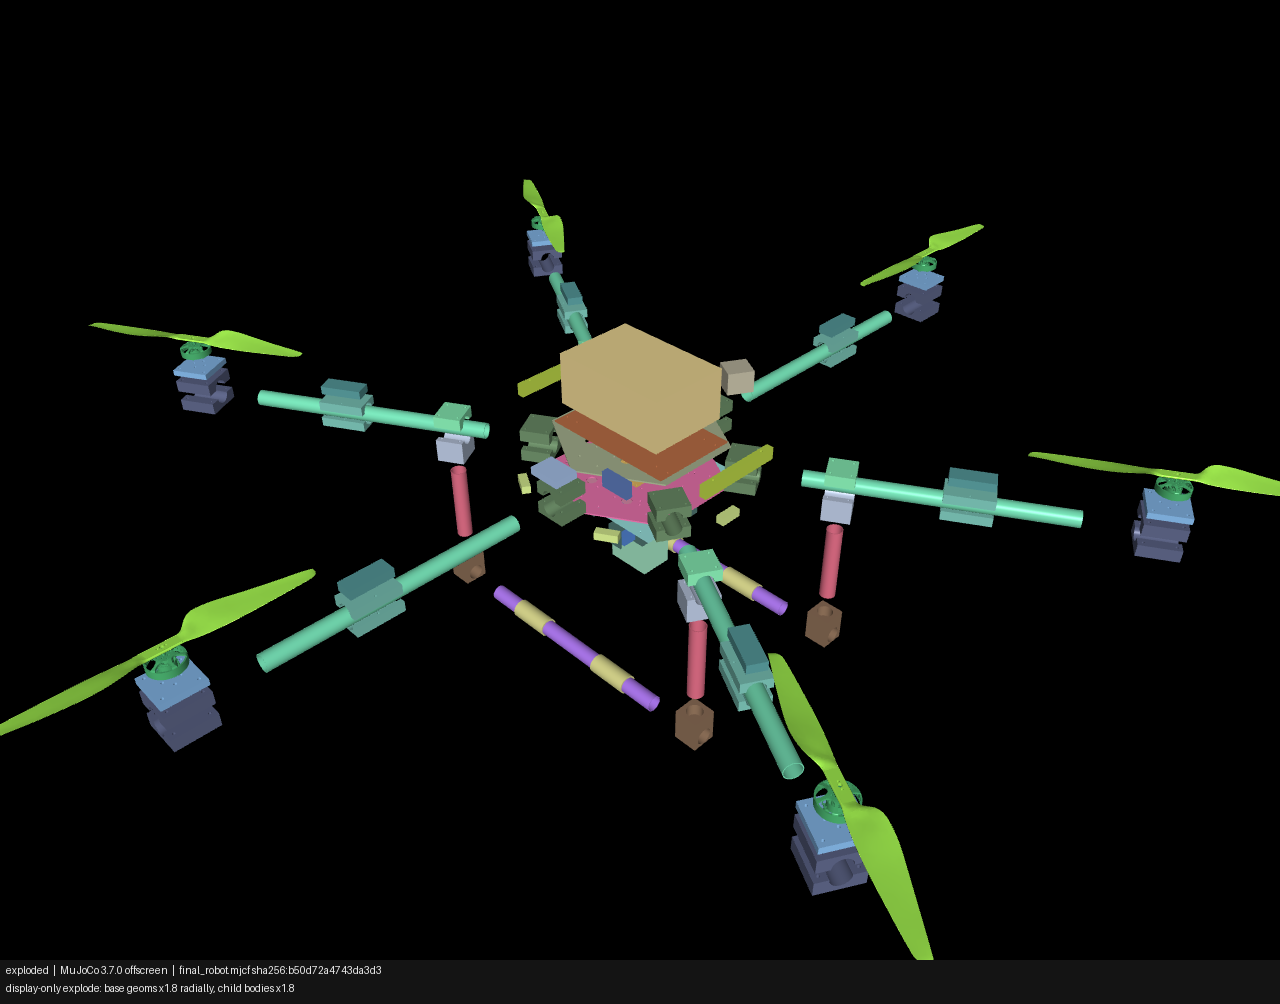
The run's render of the same robot until then. Drag to orbit, pinch to zoom, tap a part to name it.
Integrated assembly from final_robot.step: 121 placed parts, 32 distinct parts, one node per part named as in the assemblyHide
Integrated assembly from final_robot.step: 121 placed parts, 32 distinct parts, one node per part named as in the assembly
Source
Derived by anubis.presentation.model3d (OCCT BRepMesh + gltfpack quantization) + gltfpack meshopt (EXT_meshopt_compression) occt 7.9.3.1, gltfpack 1.3 from:
- workspace/design_package/integration/final_robot.step(locked until release)sha256 5a2a3d52b8eed56f…
- workspace/design_package/integration/component_instance_manifest.jsonsha256 bbf3a77bf4e2f7fb…
- workspace/design_package/mechanical/mechanical_assembly_spec.jsonsha256 560e66c267d0462f…
- workspace/design_package/bom/design_bom.jsonsha256 e75ee6cf308682f5…
- workspace/design_package/electrical/component_manifest.jsonsha256 a877a7a2d6825c55…
- workspace/design_package/integration/board_placement.jsonsha256 e4ec773ae45cf504…
- workspace/design_package/integration/bought_part_geometry.jsonsha256 2b657ce109d31e65…
Agricultural mapping hexacopter, mechanical assembly
Commercial-grade hexacopter for multispectral crop-health mapping with a 3 kg payload capacity and 12S LiPo power system.Hide
Commercial-grade hexacopter for multispectral crop-health mapping with a 3 kg payload capacity and 12S LiPo power system.
- Required operating speed
- 5 m/s
- Required payload
- 3 kg
- Required runtime target
- 0.5 h
What it is made of
ComputerHolybro Pixhawk 6X (Standard Baseboard)
- Holybro Pixhawk 6X (Standard Baseboard)
runs the robot's software
- Processor
- STM32H753
Bought parts6× T-MOTOR MN5008 KV170, 6× T-MOTOR ALPHA 60A 12S V1.2, 6× T-MOTOR P18*6.1 CF Polish +15 more18
actuator
- 6×T-MOTOR MN5008 KV170maker model
T-MOTOR MN5008 KV170 brushless motor
- 6×T-MOTOR ALPHA 60A 12S V1.2datasheet envelope
T-MOTOR ALPHA 60A 12S V1.2 electronic speed controller
auxiliary
- 6×T-MOTOR P18*6.1 CF Polishmaker model
T-MOTOR P18*6.1 CF Polish propeller (two blades, integrated)
sensor
- Holybro PM08-CANdatasheet envelope
- LightWare LiDAR SF45/Bdatasheet envelope
- 4×Benewake TFmini-Sdatasheet envelope
- AgEagle / MicaSense RedEdge-Pdatasheet envelope
MicaSense RedEdge-P multispectral camera
- Texas Instruments TMP1075DGKRnot placed
- Holybro H-RTK ZED-F9P (RM3100 Compass)not placed
- Benewake TF03-180not placed
compute
- Holybro Pixhawk 6X (Standard Baseboard)datasheet envelope
Holybro Pixhawk 6X (Pixhawk Autopilot v6X standard) flight controller
communication
- RFDesign RFD900xdatasheet envelope
- Holybro Remote ID Module (ArduRemoteID, ESP32-C3)not placed
- Texas Instruments SN65HVD230Dnot placed
placed without an electrical record
- Tattu (Grepow) Tattu NEO Compact 26000mAh 12S1Pdatasheet envelope
Tattu NEO Compact 26000 mAh 12S1P LiPo pack
- MicaSense (AgEagle) DLS 2datasheet envelope
MicaSense DLS 2 downwelling light sensor and GPS
- 4×Enidine (ITT) CR2-400-Ddatasheet envelope
ITT Enidine CR2-400 compact wire-rope isolator
battery
- Tattu (Grepow) Tattu NEO Compact 33000mAh 12S1Pnot placed
Shapes as the package labels them: workspace/design_package/integration/bought_part_geometry.json
BatteryTattu (Grepow) Tattu NEO Compact 33000mAh 12S1P
- Tattu (Grepow) Tattu NEO Compact 33000mAh 12S1Pnot placed
12S LiPo pack candidate - high capacity.
- Chemistry
- lipo
- Cells in series
- 12
- Nominal voltage
- 44.4 V
- Capacity
- 33 Ah
- Energy (nameplate)
- 1465 Wh
- Pack mass
- 5.148 kg
- Connector
- AS150U-F
- Swappable
- not recorded
Custom boardspcb_layout
- pcb_layout
custom circuit board designed for this robot
36 parts
- AMASS AS150UJ_PACK · connector
- Texas Instruments LM74700QDBVRQ1U_RP · protection
- Texas Instruments CSD19536KTTQ_RP1, Q_RP2, Q_HS, Q_MK1, Q_MK2 · protection
- Texas Instruments LM5069MMX-2U_HS, U_MK · protection
- Bourns SMLJ58AD_TVS, D_TVS_M · protection
- Bourns SMLJ6.0AD_TVS5 · protection
- Bourns SMLJ13AD_TVS12 · protection
- Vishay Dale WSL2512R0200FEAR_SH · passive
- Texas Instruments INA228AIDGSRU_IMON · sensor
- Texas Instruments LM76005RNPRU_5V · power_conversion
- Texas Instruments LM76003RNPTU_12V · power_conversion
- Texas Instruments TPS259621DDAU_EF1..U_EF4 · protection
- Bourns SRP1265A-8R2ML_5V · passive
- Bourns SRP1265A-220ML_12V · passive
- KEMET C0805C104K4RACTUC_GEN:0.1u@16V · passive
- KEMET C0805C105K4RACTUC_GEN:1u@16V · passive
- KEMET C0805C332K4RACTUC_GEN:3300p@16V · passive
- KEMET C0805C474K4RACTUC_GEN:0.47u@16V · passive
- KEMET C1210C106K3RACTUC_GEN:10u@25V · passive
- KEMET C1210C225K1RACTUC_GEN:2.2u@100V · passive
- KEMET C1210C226K3RACTUC_GEN:22u@25V · passive
- Vishay CRCW080510K0FKEAR_GEN:10k · passive
- Vishay CRCW0805110KFKEAR_GEN:110k · passive
- Vishay CRCW080527K4FKEAR_GEN:27k4 · passive
- Vishay CRCW08052K67FKEAR_GEN:2k67 · passive
- Vishay CRCW080542K2FKEAR_GEN:42k2 · passive
- Vishay CRCW0805453RFKEAR_GEN:453R · passive
- Vishay CRCW080549K9FKEAR_GEN:49k9 · passive
- Vishay CRCW08054K75FKEAR_GEN:4k75 · passive
- Vishay CRCW080576K8FKEAR_GEN:76k8 · passive
- Vishay CRCW0805909RFKEAR_GEN:909R · passive
- Vishay CRCW080595K3FKEAR_GEN:95k3 · passive
- JST SM04B-GHS-TBJ_GH · connector
- JST SM02B-GHS-TBJ_GH2 · connector
- Wuerth Elektronik 61300311121J_HDR3 · connector
- Wuerth Elektronik 61300811121J_HDR8 · connector
Made parts by material57× cfrp_cfs_ri_3mm, 12× cfrp_rollwrapped_tube, 18× pa12_sls_mjf3
- 57×cfrp_cfs_ri_3mm
material of the made parts below
13 parts
- Hub arm clamp half, laminated CFRP×12 · carbon_fiber_composite_fabrication
- Battery tray, CFRP×1 · carbon_fiber_composite_fabrication
- Motor boom clamp half, laminated CFRP×12 · carbon_fiber_composite_fabrication
- Isolated camera sub-tray, CFRP×1 · carbon_fiber_composite_fabrication
- Lower hub plate, hexagonal CFRP×1 · carbon_fiber_composite_fabrication
- Upper hub plate, hexagonal CFRP×1 · carbon_fiber_composite_fabrication
- Isolator L-bracket, CFRP×8 · carbon_fiber_composite_fabrication
- Isolator deck, CFRP×1 · carbon_fiber_composite_fabrication
- Landing leg clamp, lower half with leg socket, laminated CFRP×4 · carbon_fiber_composite_fabrication
- Landing leg clamp, upper half, laminated CFRP×4 · carbon_fiber_composite_fabrication
- Landing gear elbow, laminated CFRP×4 · carbon_fiber_composite_fabrication
- Motor mounting plate, laminated CFRP×6 · carbon_fiber_composite_fabrication
- Slotted underbody payload rail, CFRP×2 · carbon_fiber_composite_fabrication
- 12×cfrp_rollwrapped_tube
material of the made parts below
3 parts
- Arm tube, 30 x 27 mm roll-wrapped CFRP×6 · carbon_fiber_composite_fabrication
- Landing leg tube, 30 x 27 mm roll-wrapped CFRP×4 · carbon_fiber_composite_fabrication
- Landing skid tube, 30 x 27 mm roll-wrapped CFRP×2 · carbon_fiber_composite_fabrication
- 18×pa12_sls_mjf
material of the made parts below
3 parts
- Battery end retainer, PA12×2 · sls_or_mjf_pa12
- ESC saddle half, PA12×12 · sls_or_mjf_pa12
- Landing skid wear sleeve, PA12×4 · sls_or_mjf_pa12
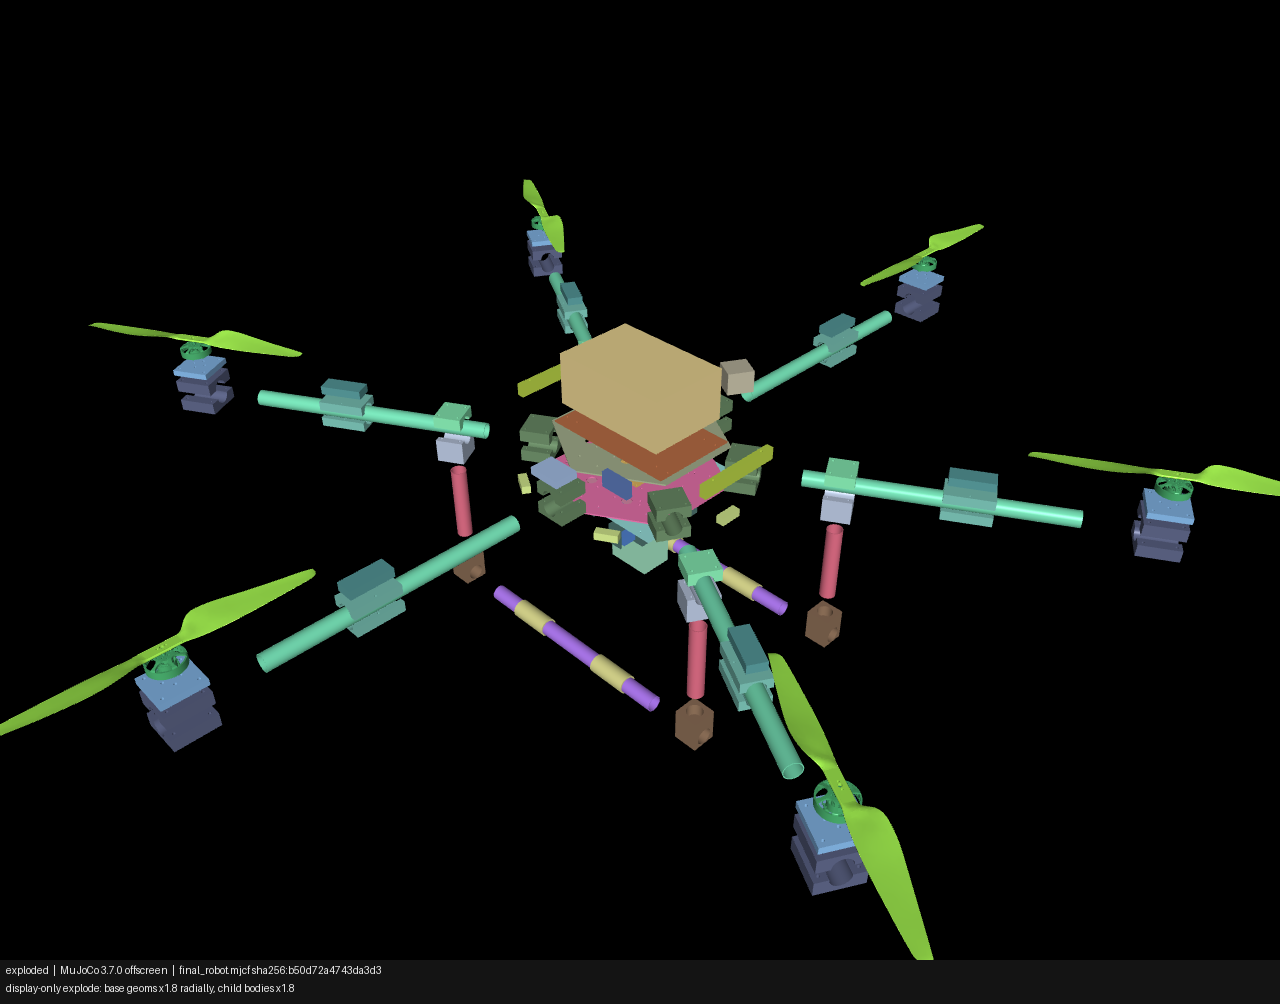
Stage 2F.5 visual review render: workspace/design_package/integration/visual_review/exploded.pngHide
Stage 2F.5 visual review render: workspace/design_package/integration/visual_review/exploded.png
Source
Derived by byte_copy 1 from:
- workspace/design_package/integration/visual_review/exploded.pngsha256 50182279344db1a8…
Open items(19)
Spec
A hexacopter agricultural mapping drone carrying a multispectral camera, 3 kg payload, brushless motors, GPS and IMU, 12 S LiPo, PA12 and carbon-fibre, flies over fields to survey crop health. Medium volume. BOM under 6000 USD.Hide
A hexacopter agricultural mapping drone carrying a multispectral camera, 3 kg payload, brushless motors, GPS and IMU, 12 S LiPo, PA12 and carbon-fibre, flies over fields to survey crop health. Medium volume. BOM under 6000 USD.
Assumptions(45)
- electronics_requirements.motor_count6
Source: Derived by Anubis: A conventional hexacopter has six independently driven rotors and six propulsion motors.
- electronics_requirements.battery_voltage_nominal_v44.4
Source: Normalised by Anubis from your description: 12S LiPo nominal voltage = 12 × 3.7 V = 44.4 V.
- class_requirements.payload_conditioned_endurance_h0.5
- class_requirements.operating_wind_ms8.94
- mission_requirements.front_overlap_min_pct75
Source: Inferred by Anubis research: MicaSense recommends at least 75 percent frontlap.
- mission_requirements.side_overlap_min_pct75
Source: Inferred by Anubis research: MicaSense recommends at least 75 percent sidelap.
- mission_requirements.multispectral_gsd_target_mm_per_px40
- mission_requirements.nominal_mapping_speed_ms5
Source: Inferred by Anubis research: 5 m/s is within published multispectral agricultural acquisition practice and must still satisfy overlap/capture-rate constraints. (also cites: research:2025_rededge_p_onion_yield)
- mission_requirements.positioning_requirementrtk_or_ppk_centimeter_class
- robot_class.primary_classaerial
Source: Normalised by Anubis from your description (from hexacopter agricultural mapping drone)
- robot_class.subtypehexacopter_agricultural_mapping
Source: Normalised by Anubis from your description (from hexacopter agricultural mapping drone)
- robot_class.mobilitymobile
Source: Derived by Anubis (from drone ... flies over fields)
- robot_class.kinematics.configuration_dof6
Source: Derived by Anubis (from hexacopter)
- robot_class.kinematics.floating_base_dof6
Source: Derived by Anubis (from hexacopter)
- robot_class.kinematics.control_input_count6
Source: Derived by Anubis (from hexacopter)
- robot_class.kinematics.mechanical_joint_count0
Source: Derived by Anubis (from hexacopter)
- robot_class.kinematics.generalized_coordinate_count6
Source: Derived by Anubis (from hexacopter)
- class_requirements.kindaerial
Source: Derived by Anubis (from hexacopter agricultural mapping drone)
- class_requirements.rotor_count6
Source: Derived by Anubis (from hexacopter)
- class_requirements.temperature_range_c[-15,50]
- class_requirements.camera_resolution_mp1.58
- class_requirements.gimbal_axes0
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- class_requirements.ground_sampling_distance_mm_per_px38.5
- class_requirements.obstacle_sensing_coverageomnidirectional
- class_requirements.gps_denied_behaviorabort_mapping_and_execute_controlled_landing_if_navigation_solution_is_unreliable
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- class_requirements.lost_link_behaviorautomatic_return_to_home
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- class_requirements.return_to_home_behaviorautomatic_on_lost_link_or_low_battery
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- class_requirements.controlled_landingtrue
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- class_requirements.geofence_behaviorenforce_planned_field_boundary_and_altitude_limits
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- task_requirements.primary_taskmultispectral crop-health mapping
Source: Normalised by Anubis from your description (from multispectral camera ... survey crop health)
- task_requirements.operating_environmentoutdoor_terrain
Source: Derived by Anubis (from flies over fields)
- task_requirements.operating_speed_ms5
Source: Inferred by Anubis research: the curated IR attributes it to this source; this correction did not re-retrieve the source
- task_requirements.runtime_target_hours0.5
- electronics_requirements.custom_silicon_requiredfalse
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- electronics_requirements.sbc_requiredfalse
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- electronics_requirements.communication_protocols["ethernet"]
- control_requirements.navigationtrue
Source: Derived by Anubis (from flies over fields to survey crop health)
- control_requirements.manipulationfalse
Source: Derived by Anubis (from mapping drone carrying a multispectral camera)
- control_requirements.safety_stop_requiredfalse
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- control_requirements.vla_policy_requiredfalse
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- manufacturing_requirements.production_volumemedium_volume_100_1000
Source: Normalised by Anubis from your description (from Medium volume)
- manufacturing_requirements.dfm_constraints["carbon-fiber primary load-bearing structure","PA12 non-primary structural housings/covers via SLS or MJF","serviceable folding or modular arms","vibration-isolated camera payload interface","field-replaceable propellers and landing components"]
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- simulation_requirements.test_scenarios["30-minute mapping mission with 3 kg payload","grid-survey path tracking at 5 m/s","crosswind path tracking up to 8.94 m/s","single-motor failure with controlled recovery or landing","lost-command-link automatic return-to-home","low-battery return-to-home and controlled landing","RTK degradation and GNSS-loss handling","terrain-following over variable field elevation","obstacle detection and avoidance during mapping","camera-trigger timing and 75-percent front/side overlap verification","payload vibration and image-motion-blur assessment"]
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- safety_requirements.estop_hardware_requiredfalse
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable
- safety_requirements.estop_software_requiredfalse
Source: Inferred by Anubis research: PROJECT-AUTHORED VALUE, a labelled assumption: the value as the project's hand-written curated IR states it (sha256 ae82ea35...); no customer statement and no retrieved external source supports it; it is the project's, never the customer's, and is changeable