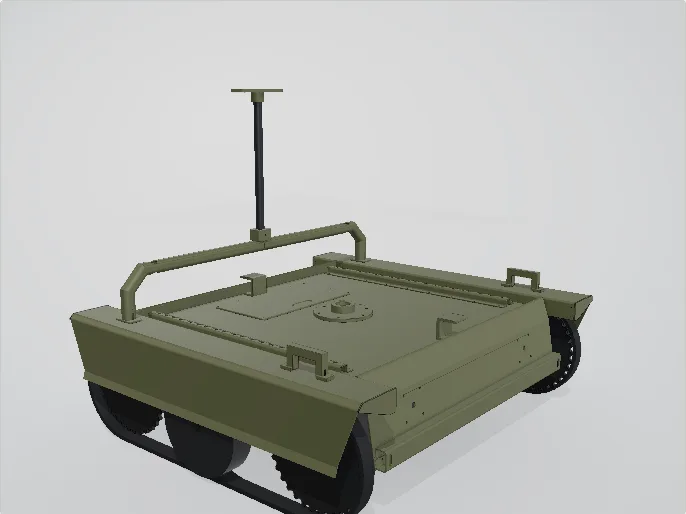
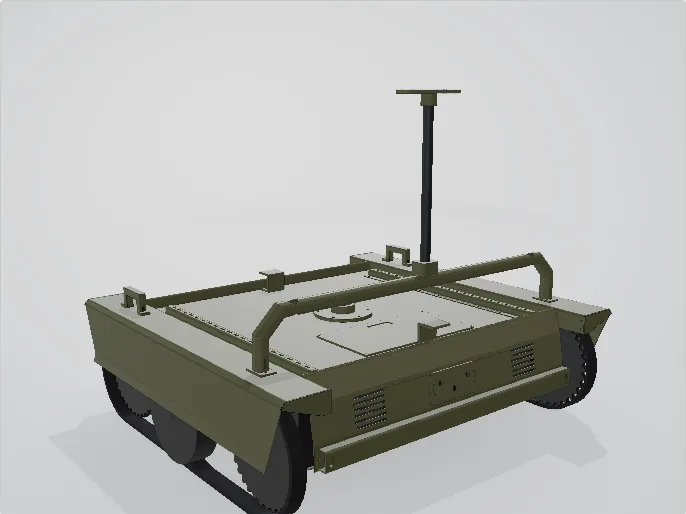
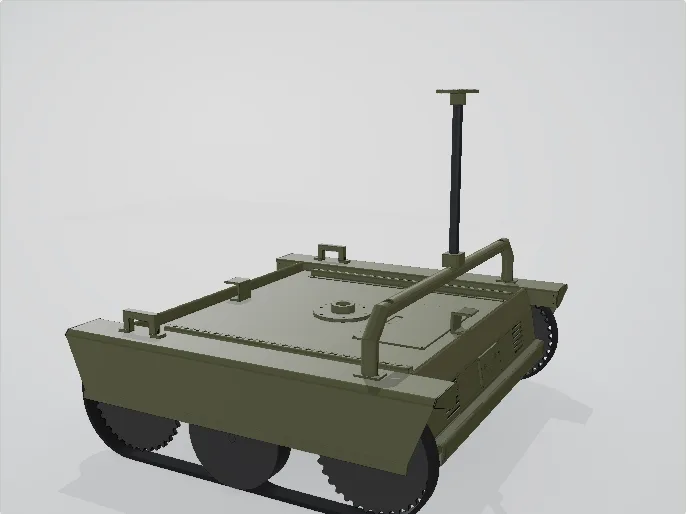
An unarmed, remotely driven tracked ground rover for military reconnaissance and route survey. It carries a 15 kg pan-tilt payload with day and thermal cameras. An operator drives it from an operator control unit over an encrypted radio link with up to 1 km line of sight. Missions last 4 hours on a 48 V Li-ion battery. It must handle rough outdoor terrain with 30 degree slopes and 20 cm steps. It has an IP67 aluminium hull, is built in low volume, and the BOM must stay under 25000 USD.
The design so far
Overall size
1,339 × 1,198 × 1,100 mm
Parts in the 3D model
107
Bill of materials lines
53
Circuit boards
1
This design is not finished. Anubis keeps working on it, and this page shows its latest state. Request a pilot to have Anubis design your robot.
Drive it
Drive the Unarmed, remotely driven tracked ground rover in a physics simulation that runs in your browser (MuJoCo)